Week 41, 2026: the plan
The rover
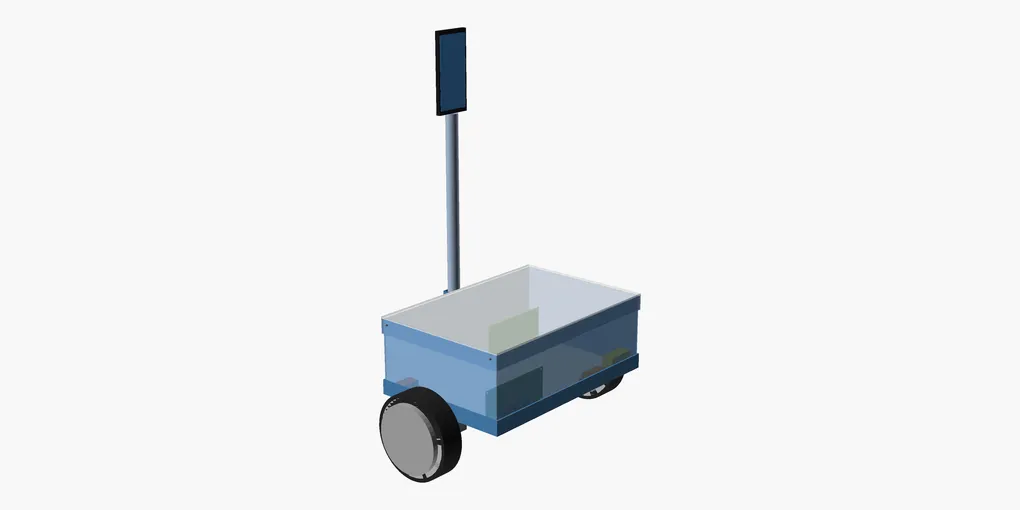
The rover is two-wheeled and self-balancing, built around a single battery module from a Mitsubishi i-MiEV electric car and two 6.5” hoverboard hub motors. The module lies flat between the wheels in a welded steel tub with plastic walls and a lid. The axle saddles are cut out of a hoverboard’s cast frame and bolted under the tub’s lip, which keeps the factory clamp plates and the motors’ anti-rotation flats. The controller is a RoboDurden Gen2.1 board, and a tall pole carries a phone as a camera.
The OpenSCAD model draws the assembly, lays the steel out flat as a cut list, and computes the balancing numbers from the same placements it draws.
Before any steel is cut, the module and the axle saddle need measuring: the module dimensions in the model come from GS Yuasa’s datasheet for the four-cell module, and no drawing of the saddle exists.
Better tools
The rover frame means more welding and more cut tube. The angle grinder cuts tube, but it makes a lot of mess, so this week I want to find a cleaner way to cut it, and to try welding with gas.
Last week
Last week’s plan had three jobs:
- The pack is open and one eight-cell module is out. ✅
- The wheels have not spun on it yet. ❌
- The cradle is published as its own OpenSCAD project. ✅
This week
Two jobs:
- Design the rover frame.
- Upgrade the workshop tools: try welding with shielding gas, and find a better way to cut steel tube than the angle grinder.